UC DAVIS CHPS LAB
  • Home
  • Research
  • Publications
  • People
  • Prospective Students
  • Home
  • Research
  • Publications
  • People
  • Prospective Students

Funding

Our research is only possible with the funding provided by a broad range of grants and industry collaborations. We are deeply thankful to all the entities listed below.
Picture
Active Grants

  • "NSF Center for Pandemic Insight (NSF CPI)" (more information here), NSF, 09/01/2024 - 08/31/2031
  • "NCS-FO: Understanding the computations the brain performs during choice", NSF, 09/01/2023 - 08/31/2027
  • "FireFly: AI-Assisted Ground-Air Wildfire Early Warning System" (more information here), CITRIS-CDSS Innovation Fellowship and AIC Award, 01/01/2026-12/31/2027
  • "System-2-Aligned Open-World World Modeling and Deliberative Autonomy for Human–UAV Teams", GGCS Ignite Collaboration Initiation Award, 2026-2027 
  • "Robotic Harvesting: Multi-Camera Fruit Detection Under Heavy Occlusion", Washington Tree Fruit Research Commission, 2026-2027 
  • "An information-enabled design framework for adaptive flight with an avian-like morphing wing", CITRIS, 07/01/2026-06/30/2027​

Current Projects

FireFly: AI-Assisted Groud-Air Wildfire Early Warning System
The expansion of the wildland–urban interface, together with a changing climate, has made wildfires an increasingly severe threat to communities and ecosystems. Because a small ignition can grow into a destructive fire within minutes, effective wildfire response depends on early detection, rapid confirmation, and accurate localization. FIREFLY: AI-Assisted Ground–Air Wildfire Early Warning is developing an integrated system that combines networks of low-cost, solar-powered ground sensors with autonomous uncrewed aerial vehicles (UAVs). The ground sensors continuously monitor chemical and environmental signals associated with emerging fires; when a potential ignition is detected, a UAV equipped with visible and thermal cameras and onboard chemical sensors is dispatched to locate the source and confirm or dismiss the alert. By fusing ground and aerial observations with AI and wind information, FIREFLY aims to provide rapid, reliable, and affordable early warning across large, wildfire-prone areas while minimizing false alarms. The system is being developed and field-tested in collaboration with Dr. Anthony Wexler at the Air Quality Research Center and Duane Strawser at the Grass Valley Fire Department. This research builds on earlier projects supported by CITRIS through "Uncrewed Aerial Vehicle Swarms for Large-Scale and Real-Time Air Toxic Measurement near Wildland-Urban-Interface Fires" (01/01/2022 – 12/31/2022), by NASA throught the grant "Integrated System and Predictive Model to Assess Air Quality and Rapidly Pinpoint Emerging Sources" (01/24/2025-07/24/2025) and by Sony throught the grant "Unmanned Aerial Vehicle Swarms for Large-Scale, Real-Time, and Intelligent Disaster Responses" (06/17/2021 - 09/30/2025) and is currently supported by CITRIS.
Uncrewed Aerial System for Precision Agriculture
Orchards present both promising opportunities and difficult challenges for agricultural robotics. Autonomous robots could help growers monitor crop health, estimate yields, and harvest fruit more efficiently, but dense foliage, narrow spaces between trees, and unreliable GPS reception make navigation challenging. This project combines machine learning and control theory to enable reliable uncrewed aerial vehicle (UAV) operation in these complex environments. The research focuses on three connected challenges: navigating within orchards with limited or unavailable GPS, coordinating UAVs with uncrewed ground vehicles (UGVs), and maintaining safe and stable flight in gusty and turbulent winds. A key direction is to use aerial imagery to build detailed three-dimensional orchard maps that support both UAV navigation and ground-based tasks such as robotic fruit harvesting. Sharing information between aerial and ground robots could help harvesters locate fruit and plan their work, connecting crop observations directly to agricultural operations. Together, these capabilities aim to improve the reliability and usefulness of robotic systems in orchards, supporting more informed management and efficient harvesting. The research is conducted in collaboration with Dr. Stavros Vougioukas (BAE, UC Davis). It was previously supported by NSF and USDA through "AI Institute: Next Generation Food Systems" (09/01/2020 - 08/31/2026) and is currently supported by WTFRC.
Robotics & UAVs for Pre-Emergence Pandemic Surveillance
Understanding how pathogens circulate in wildlife—and when they might spread to humans—is essential to preventing future pandemics. As part of the NSF Center for Pandemic Insights (CPI), our group develops autonomous robotic systems, primarily uncrewed aerial vehicles (UAVs), to study wildlife populations and their environments before outbreaks occur. We design UAV platforms with interchangeable sensor payloads and navigation capabilities suited to rugged, hard-to-access habitats, enabling repeated observations while minimizing disturbance to wildlife. These systems contribute to CPI’s broader sensor network by collecting complementary visual, thermal, and environmental data. Current research includes using thermal imaging to estimate bat colony size and track when bats leave their roosts; visible-light imaging to study the behavior and health of seals and sea lions at coastal resting sites, including changes potentially associated with avian influenza; and air-sampling systems that collect successive samples for analysis of airborne viruses in bat caves. We also investigate AI-based identification of individual animals to connect observations over time and better understand changes in wildlife populations. By bringing together robotics, wildlife ecology, virology, and artificial intelligence, this work aims to reveal early ecological and behavioral signs of disease emergence and improve models of the risk that animal pathogens will spread to humans. The project is conducted in collaboration with Dr. Christine K. Johnson (Vet Med, UC Davis) and Dr. Simon Anthony (Vet Med, UC Davis) and is supported by the NSF.
Picture
Causal Explainable AI
As artificial intelligence (AI) takes on a larger role in control and decision-making, people need to understand its recommendations and recognize when to rely on—or question—them. This is particularly important in applications such as healthcare, transportation, and autonomous robotics, where decisions can have significant consequences. Yet many AI models offer little insight into how they reach a decision or how that decision might change under different circumstances. This project advances the theoretical and algorithmic foundations of causal explainable AI (XAI), with a focus on explanations that help people understand and evaluate AI-generated decisions and actions. Our approach draws on research into how people seek, interpret, and assess explanations to guide what information an AI system should communicate and how it should present it. A central direction is counterfactual reasoning: explaining how an outcome would change if relevant conditions or actions were different. By accounting for causal relationships, we aim to distinguish meaningful changes that could influence an outcome from patterns that merely correlate with it. These explanations can help users compare alternatives, identify limitations, and make better-informed decisions. The broader goal is to support appropriate trust in AI, helping people judge when its recommendations are reliable and when further scrutiny or human intervention is needed. The research is conducted in collaboration with​ Dr. Xin Liu (CS, UC Davis) and Dr. Xin Chen (Industrial and Systems Engineering, Georgia Tech).  It has been supported by NSF and USDA through "AI Institute: Next Generation Food Systems" (09/01/2020 - 08/31/2026) and by NASA through "Habitats Optimized for Missions of Exploration (HOME)" (09/01/2019 - 08/31/2024).​
Picture
Real-Time Inference and Prediction of Trust in Human-Autonomy Teaming

Effective collaboration between people and autonomous systems depends on knowing when to rely on automation and when to intervene. Too little trust can lead people to reject useful assistance, while too much trust can cause them to overlook errors or rely on a system beyond its capabilities. This project investigates how trust changes during human–autonomy interactions and develops methods to estimate and predict those changes in real time. Because trust evolves with experience, system performance, and task conditions, occasional questionnaires provide only part of the picture. Our approach combines behavioral measures collected during a task with physiological signals, such as brain activity and heart rate, to capture how trust develops from one interaction to the next. Using machine learning and dynamical systems modeling, we seek to connect these observations to underlying trust states and predict how trust may respond to subsequent events. A central challenge is to develop reliable measures that can be integrated into realistic tasks with minimal disruption to the operator. These models could enable autonomous teammates to adapt their communication, explanations, or level of assistance to support trust that matches their actual capabilities and limitations, improving safety and team performance. The research is conducted in collaboration with Dr. Allie Hayman and Dr. Torin Clark at the University of Colorado Boulder. It has been supported by CITRIS through "Trust Aware Human-Machine Teaming Using Real-Time Neurophysiological Data" (01/01/2023 – 12/31/2023), by NASA through "Habitats Optimized for Missions of Exploration (HOME)" (09/01/2019 – 08/31/2024), and by the AFOSR through "Metrics and Models for Real-Time Inference and Prediction of Trust in Human-autonomy Teaming" (11/25/2022 - 06/30/2026).​
Understanding Computations Brain Performs During Choice
How does activity across different brain regions give rise to a decision, and how can we determine which neural processes actually influence the choices we make? This project develops a causal framework for studying the neural computations underlying decision-making. Using an established experimental paradigm known as the Gambling Task, we investigate how the brain evaluates potential rewards and risks and translates that information into choices. Understanding these processes could provide insight into cognitive impairments that disrupt everyday decision-making and place substantial burdens on individuals, caregivers, and society. A central challenge is to explain how patterns of brain activity evolve over time and interact across regions as a decision unfolds. Our approach combines machine learning with system identification—methods for discovering dynamical models from measured data—to uncover these patterns and relate them to behavior. We also draw on control theory to investigate how targeted changes in neural activity could influence decisions, helping distinguish causal mechanisms from correlations. The goal is to develop interpretable, predictive models that connect brain activity to cognitive function and provide a foundation for future approaches to restoring impaired decision-making. The research is conducted in collaboration with Dr. Karen Moxon (BME, UC Davis), Dr. Xin Liu (CS, UC Davis), Dr. Jochen Ditterich (Center for Neuroscience, UC Davis), and Dr. Ignacio Saez (Mount Sinai). It was previously supported by NSF through "NCS-FO: Identification and Control of Neural Cognitive Systems" (10/01/2020 – 09/30/2024) and continues with support from an additional NSF award.

Completed Projects

XCPS: Explainable Cyber-Physical Systems (09/2019-08/2024)
 

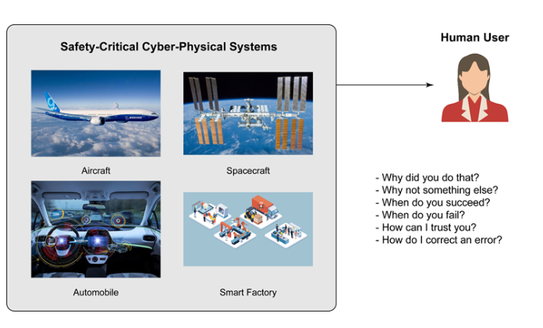
Greater complexity in (semi-)autonomous systems is a double-edged sword. More sophisticated automation may increase, rather than decrease, the difficulty for a human operator to comprehend the system’s behaviors. The problem may be exacerbated when the operator is denied a direct observation of the internal functioning of the system, thus having to surmise what may be occurring from sensor data. This can be daunting, mainly when some sensors are susceptible to failure. Many such systems, e.g., driverless cars, nuclear power plants, and spacecraft, are safety-critical: a small error may lead to unintended, highly regrettable consequences. This project aimed to enable safety-critical (semi-)autonomous systems to inspect their observations and consequently explain themselves in a language understandable by humans. This project was supported by NASA under the grant "Habitats Optimized for Missions of Exploration (HOME)" (09/01/2019 - 08/31/2024).
Picture
 Safety-Assured Imitation Learning for Vision-Based Control of UAS in Complex, GPS-Denied Environments (03/20-08/22)
Many future military (e.g., scouting and patrolling) and civilian (e.g., search-and-rescue) missions require unmanned aerial systems (UAS) that can fly inside complex and possibly GPS-denied environments (e.g., a forest) safely and effectively. This project aimed to tackle one technical challenge hampering the future development and deployment of such UAS: how to guarantee the safety of the UAS, e.g., avoiding collision with nearby obstacles, while maintaining its performance. A natural starting point is imitation learning, which allows an agent to learn what actions to take in an environment from the demonstrations of a human expert. However, even though all expert demonstrations are technically safe in a traditional imitation learning setting, the agent may generate an unsafe control policy. This project aimed to integrate imitation learning and formal methods at the fundamental level to develop safety-assured learning strategies. ONR supported this project under the grant "Safety-Assured Apprenticeship Learning for Vision-Based Control of UAS in Riverine Environments" (03/01/2020 - 08/31/2022).
Network-based Neurophysiological and Psychophysiological Metrics of Human Trust Dynamics When Teamed with Autonomy (04/21-03/22)
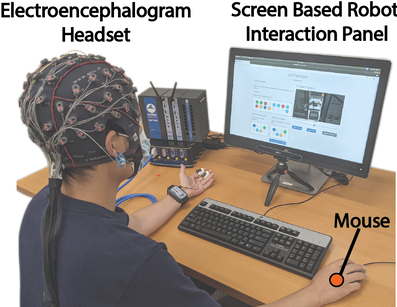
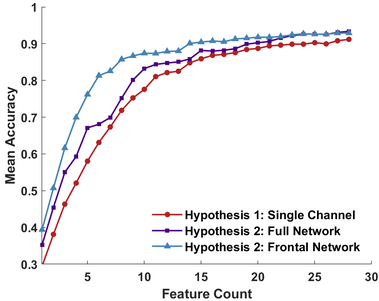
The objective of this collaborative project was to develop neurophysiological and psychophysiological measurement-based trust metrics with a particular focus on dynamic assessment of trust in human-autonomy teaming tasks. Specifically, this project integrated the fields of cognitive science, network science, and human factors to (1) develop an experimental methodology to study human trust dynamics in human-autonomy teaming scenarios and (2) investigate if a series of network-based metrics that are derived from multi-modal neurophysiological and psychophysiological measurements, e.g., EEG and fNIRS, can be used to infer human trust dynamically. Our collaborators were Dr. Allie Anderson and Dr. Torin Clark at CU Boulder. This project was supported by AFOSR under the grant "Network-based Neurophysiological and Psychophysiological Metrics of Human Trust Dynamics When Teamed with Autonomy" (04/01/2021 - 09/30/2022)
Picture
Picture
The left figure shows our human-autonomy teaming setup, while the right figure shows the performances of our classifiers evaluated against test data.
Reducing Pesticide Risk by Using Drones to Enhance Performance of Biological Control (07/18-12/21)
Our world is plagued with large-scale ecological disasters. Tragic examples include the Fukushima I Nuclear Power Plant calamity and the Deepwater Horizon oil spill. Today, these disasters may be partially mitigated by teams of humans working in hazardous and labor-intensive environments. To combat these destructive environmental processes, we envision developing a network of UAVs to combat these disasters while keeping humans at a safe distance. This project was part of our effort to achieve this long-term goal. In this project, we developed a UAS platform, including a UAV and a predatory mite dispensing device, that can precisely and autonomously disperse predatory mites onto infested plants, even in challenging situations like strong winds! Our main collaborator was Dr. Christian Nansen in the Department of Entomology and Nematology. Our project has been featured by two local news stations, ABC10 and CBS13, and ASME. The California DPR supported this project under the grant "Reducing Pesticide Risk by Using Drones to Enhance Performance of Biological Control" (07/01/18-12/31/21).
Smart Energy Management for Uncrewed Aerial System Operation in Complex Military Missions  (07/18-06/20)

​In recent years, uncrewed aerial systems (UAS) and other uncrewed systems (UxS) have found their way onto the battleground to extend the reach of military forces, providing essential intelligence, surveillance, and reconnaissance (ISR) as well as payload delivery and recovery. The increasing capability of such systems, tiny and lightweight UxS swarms, has offered the Navy, the Marine Corps, and other military branches a significant opportunity to potentially reduce cost, increase system resiliency, and enhance operation effectiveness. However, energy efficiency is one fundamental challenge impeding the broad deployment of small-scale UxS and UxS swarms, particularly in complex military missions. This project aimed to tackle this challenge by investigating the fundamental physics governing the UAS energy performance and improving the mission KPIs through energy-oriented planning and control. This was a collaborative work with Dr. Xinfan Lin. The project was funded by the NEPTUNE 1.0 Program of the ONR.
Data-Driven Personalized Training of Next-Generation Workforce (07/16-06/18)
Humans, in the role of either customers, designers, program managers, or workers, will always play a significant part in future manufacturing. However, the systems that humans interact with are becoming increasingly complicated, especially with the rise of large-scale industrial cyber-physical systems (CPSs), also called the Industrial Internet of Things (IIoT). This project aimed at developing a data-driven method of modeling and analyzing humans' manual expertise while interacting with CPSs and traditional machines. The insights gained from this project can help us build machines and CPSs that can collaborate with humans more efficiently and effectively and also allow us to facilitate knowledge transfer among generations. This was a collaborative work with Dr. Barbara Linke.
The video on the left shows the gaze data of an expert performing a manual grinding task, while the video on the right shows the gaze data of a novice performing the same task.

Location

Contact Us
2900 spafford St,
​davis, CA 95618
zdkong (at) ucdavis (dot) edu